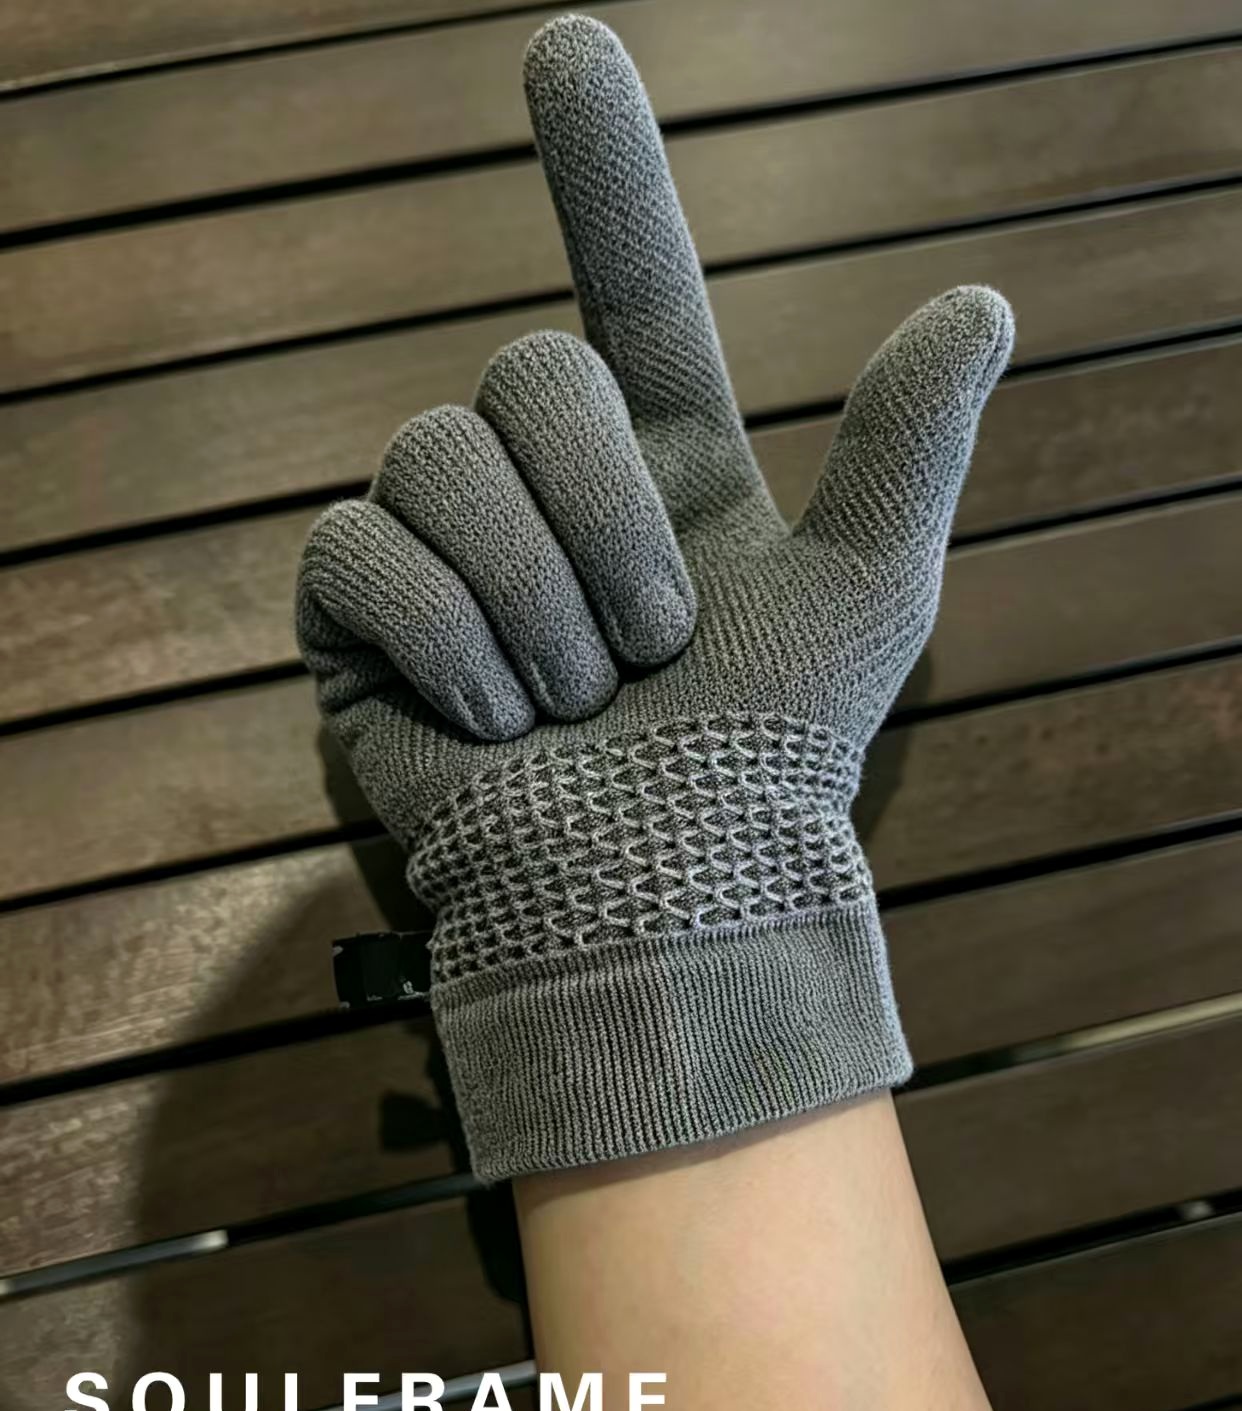
03 / DEXTEROUS HAND
Robot Dexterous-Hand Glove
Designed around finger motion, palm-and-wrist coverage and visual consistency, with structures adjusted to hand dimensions and joint locations.
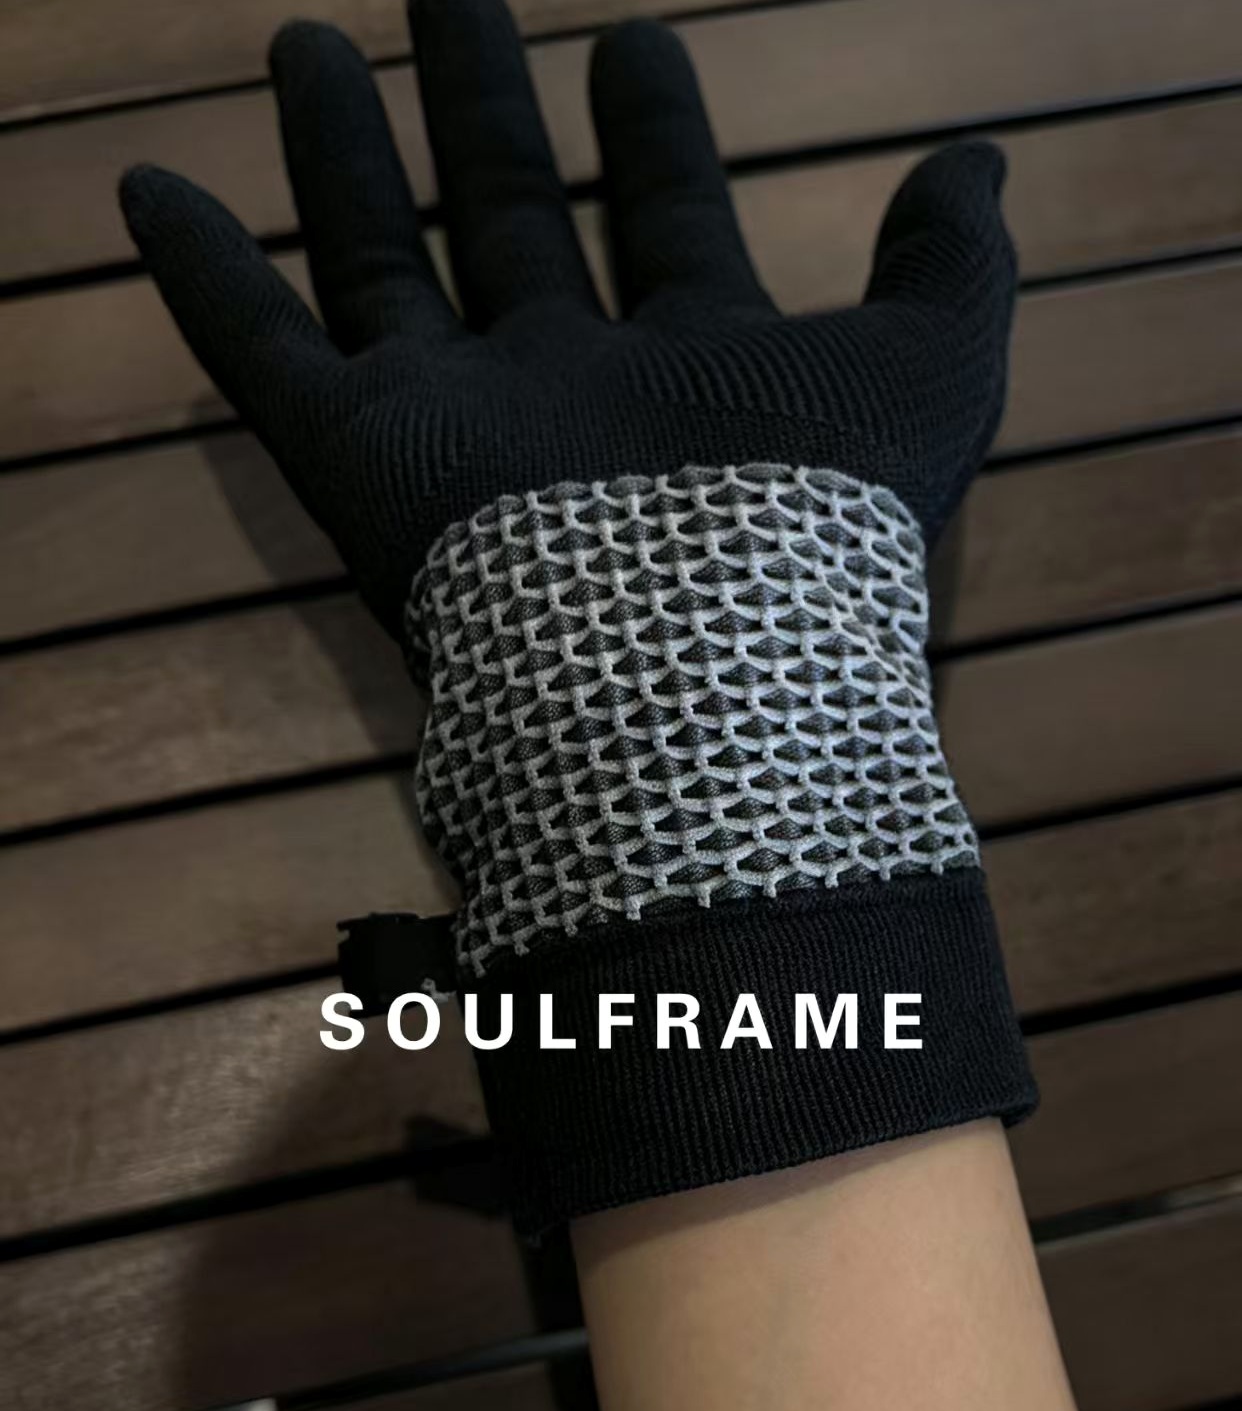
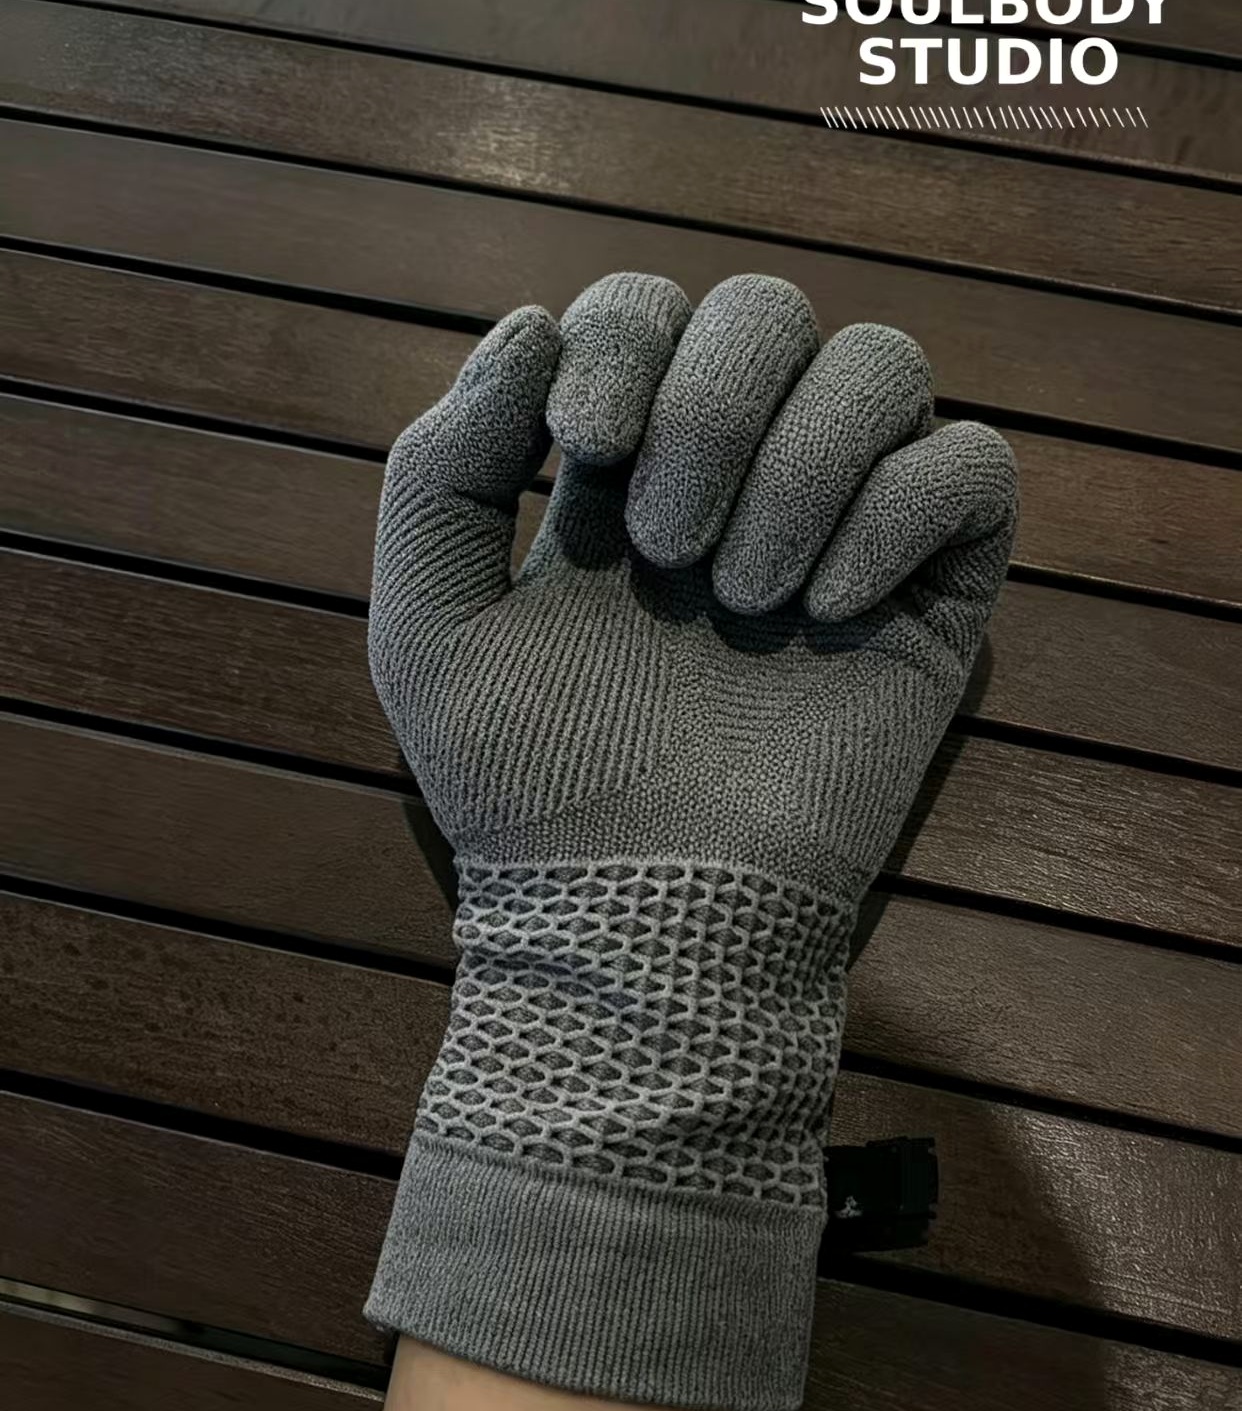
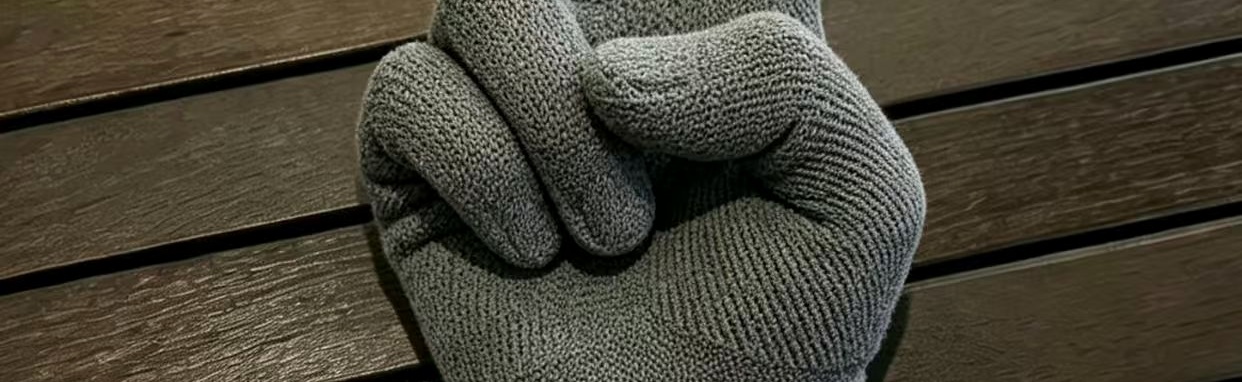
Structural features
Separate fingersIndependent sleeves support finger bending and opening.
Elastic finishA ribbed wrist provides stable, removable coverage.
Local structuresMesh or dimensional textures can be placed on palm and wrist.
Custom sizingLength, color, wrist finish, texture and branding.
Developed from your hand geometry
Send hand images, joint dimensions or 3D data.
Request assessment